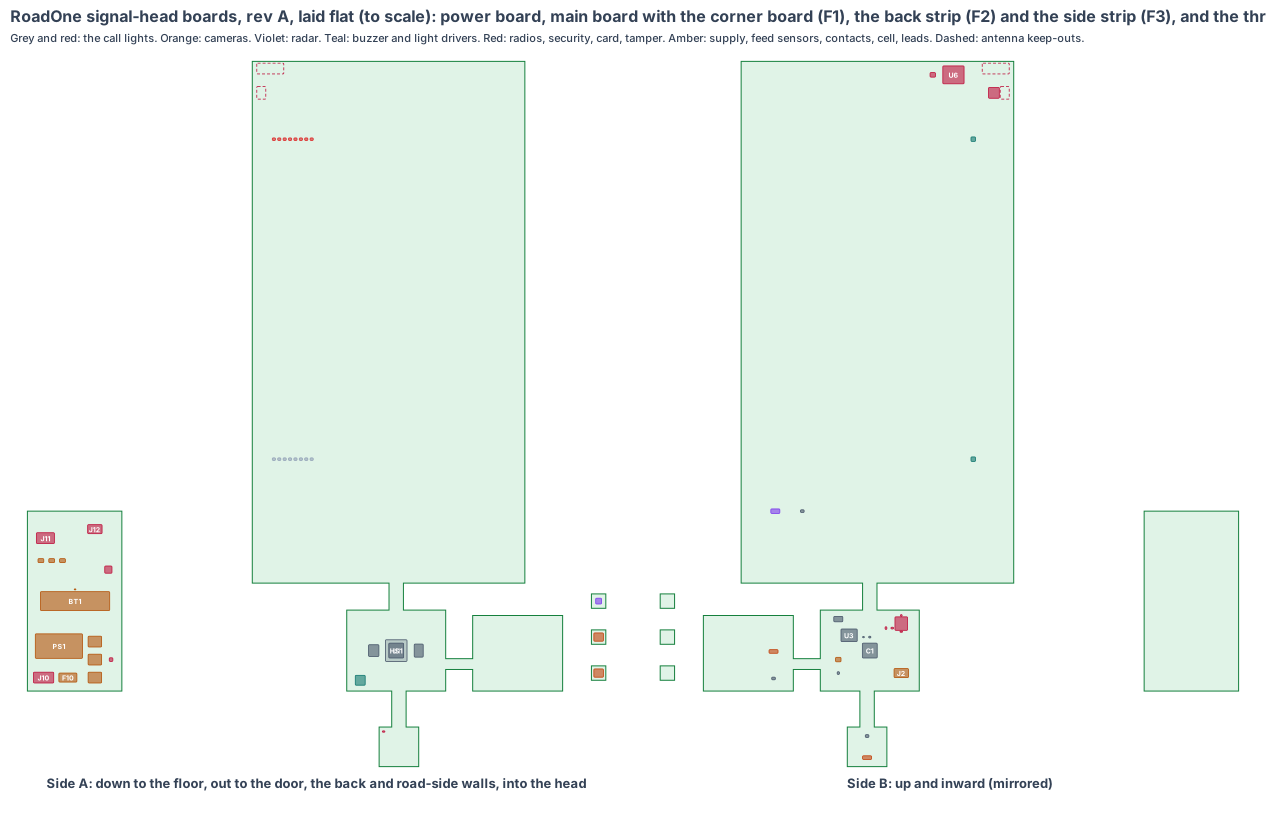
RoadOne: circuit boards of our own
What changed (4 Nov 2026). The rev A bench signal head is built from bought boards joined by leads: a Raspberry Pi 5, two Camera Module 3 Wide boards on ribbons, an HLK-LD2450 radar module, three clip-on current clamps and an ADS1115 board, an LSM6DSOX board, three relays, two NeoPixel sticks, a piezo, an ATECC608 board, a Walter LTE-M board, a PowerBoost with a LiPo and an IRM-20-5 on flying leads. RoadOne now gets boards of our own, like CricketOne and BayOne, with every chip placed straight onto them, made with every shared design-review rule from the start.
- The chips: the V2 core (Rockchip RK3576J, 4 GB LPDDR4X, 32 GB eMMC, AMPAK AP6275S Wi-Fi 6/BT module), two bare Sony IMX415 8 MP camera chips under M12 lens holders (the C1 camera on the board), a TI IWRL6432AOP 60 GHz radar chip with its antennas on the package, a Quectel BG95-M3 LTE-M module with a soldered eSIM, 16 call-light LEDs with two drivers, an SMD buzzer, an ST LSM6DSOX motion chip, the security chip and a Hall tamper switch; on the power board a Mean Well IRM-20-5 supply, three PCB current transformers on the lamp feeds with an ADS131M04 ADC, three photo-MOS controller contacts and one soldered 18650 backup cell with its charger and thermistor.
- The shape: the head’s own three 300 mm LED modules fill the front 100 mm and stay exactly as they are, driven by the controller. Our boards line the walls behind them. An 8-layer main board (110 × 90 mm) lies flat on the head floor; a small 4-layer corner board stands behind the door’s solid bottom road-side corner, below the green module, with the approach camera; a 4-layer back strip stands inside the back wall with the kerb radar, the two call-light rows and the radios; a 4-layer side strip stands inside the road-side wall with the crossing camera; a 2-layer power board on the left wall keeps 120 V on its own. Flexes F1, F2 and F3 join the main board to the others; one latched lead joins the power board.
- Two fixes in the same run:
- From a window in the head’s floor, the count line 60 m up the approach lies 88° off the floor, so no floor window could show it (lesson: window). The approach camera now looks out of the door’s bottom road-side corner, which faces the approach and is solid polycarbonate below the green module. The crossing window grew from a round 18 mm to 56 × 28, because the car over the stop line lies 70° off the road-side wall. Drawn in the CAD the same day (rev T).
- The bench design took its supply from “the head’s own feed”, but a plain head has only the three switched lamp feeds, and a supply on a lamp feed could hide a dead red module from the controller’s lamp-out check. The power board now takes an unswitched 120 V feed on a spare conductor of the head’s own signal cable (fused in the cabinet), and senses the lamp feeds with current transformers the wires pass through unbroken.
- Made from the shared rules: MEMS clocks, the latched microSD card with our software on every board, conformal coating against rain and condensation, a thermistor on the backup cell, the antennas checked near the steel pole on rev A, cameras 30 mm or more from the processor, every line of sight under 82° from its wall.
The bench signal head stays the test rig until the boards arrive.
1. The shape: five boards, three tabs
| Piece | Size | Layers | Where | What |
|---|---|---|---|---|
| Main board | 110 × 90 mm, 1.6 mm | 8 | flat on the head floor, side A 10 mm over a 3 mm aluminium L-spreader | the V2 core, card, security, motion chip, buzzer, lead header |
| Corner board | 44 × 44 mm, 1.6 mm, on F1 (274 mm) | 4 | standing 25 mm behind the door’s bottom road-side corner, 22 mm clear of the green module | approach camera tab, door tamper switch, supplies |
| Back strip | 303 × 580 mm, 1.6 mm, on F2 (44 mm) | 4 | standing 30 mm inside the back wall | kerb radar tab, two call-light rows and drivers, LTE-M with eSIM and antenna, Wi-Fi/BT |
| Side strip | 100 × 84 mm, 1.6 mm, on F3 (131 mm) | 4 | standing 30 mm inside the road-side wall | crossing camera tab and supplies |
| Sensor tabs (3) | 16 × 16 mm, 0.8 mm, on 40 mm flex hinges | 4 | each on its sensor’s axis, the lens or chip just inside its window | IMX415 (approach, crossing), IWRL6432AOP (kerb radar) |
| Power board | 105 × 200 mm, 1.6 mm | 2 | on the left wall, 120 V behind a printed shield | supply terminal, fuse, IRM-20-5, three feed sensors and ADC, three controller contacts and terminal, backup cell, charger |
Lead L1 (power board to main board: 5 V on two pairs, cell sense, contact drive) is about 0.5 m of 20 AWG with Molex Micro-Fit 3.0 6-pin latched ends.
2. What is on the boards
Main board, side A (down): RK3576J (U1) with a 24 × 24 heat block (HS1) to the aluminium L-spreader, whose upright is bolted through the back wall to the steel pole bracket; LPDDR4X (U2), eMMC (U11), the SMD buzzer (BZ1) over the tone holes.
Main board, side B (up): decoupling field (C1), RK806S power (U3), 24 MHz and 32 kHz MEMS oscillators (Y1, Y2), ATECC608B (U8), ID chip (U9), the latched microSD (J1, reached by opening the door), LSM6DSOX motion chip (U13: the head hit or turned off its approach), eFuse (U42), lead header (J2), factory pads (TP1).
Corner board: approach camera tab (U260, IMX415 under a 102° M12 lens, 25° down the approach, through a 24 × 24 window in the door corner), the door tamper Hall switch (U7) facing a magnet on the door; camera supplies (U26) and ESD (U28) on side B.
Back strip, side A (to the wall): kerb radar tab (U250, IWRL6432AOP, 30° down toward the kerb and the crossing behind the 54 × 24 radome), 8 white LEDs behind the “seen you” slot (D11–D18) and 8 red LEDs behind the officers’ confirmation slot (D21–D28), each through a printed light guide. Side B: two light drivers (U70, U71), radar supplies (U24) and ESD (U27), the AP6275S (U5) with its antenna keep-out (ANT1) at the left edge, the BG95-M3 (U6) with its eSIM (U6S) and chip antenna (ANT2) in the top-left corner, 73 to 93 mm from the steel pole.
Side strip: crossing camera tab (U200, IMX415, 25° down to the stop line and the crossing, through the 56 × 28 window); supplies (U21) and ESD (U25).
Power board (side A into the head): spring-clamp supply terminal (J10) for the unswitched feed, fuse and varistor (F10), IRM-20-5 (PS1), three PCB current transformers (CT1–CT3) that the head’s own red, amber and green feed wires pass through unbroken, the ADS131M04 ADC (U51), the 18650 holder and cell (BT1) with its thermistor (RT1), the charger (U50), three photo-MOS contacts (K1–K3) and their 4-pole spring-clamp terminal (J11) for the controller’s own detector inputs, the lead header (J12).
3. Every connection, checked
| Link | How | Checked against |
|---|---|---|
| Camera chips to RK3576J | 4-lane MIPI CSI-2 each, over F1 or F3 and the tab hinges | IMX415 data sheet: 891 Mbps per lane; at 10 fps each uses 0.83 Gbps of 3.56 |
| Radar chip | SPI and a frame interrupt over F2 | TI IWRL6432AOP data sheet |
| Lamp feeds | the head’s own feed wires through the current transformers’ windows, never cut or tapped; the ADC on SPI over L1’s partner lines | Talema AC10 and TI ADS131M04 data sheets (to read) |
| Controller | three photo-MOS contacts on the controller’s own detector inputs, on spare conductors (or a separate detector cable where the authority asks) | Panasonic AQY212 data sheet (to read); NEMA TS 2 detector inputs |
| Call lights | PWM to two constant-current drivers on the back strip | driver data sheet (to choose) |
| LTE-M | USB 2.0 and UART over F2; eSIM soldered | Quectel BG95 hardware design |
| Wi-Fi/BT | SDIO and UART over F2 | AMPAK AP6275S (RK3576 SDK default) |
| Power in | an unswitched 120 V feed, fused in the cabinet and on the board, into the class II IRM-20-5; 5 V on L1 into an eFuse at 3.5 A; L1 drops 0.03 V at 2 A | Mean Well IRM-20 data sheet |
| Card | SD bus to the RK3576J, latched socket | Amphenol 101-00660 family drawing |
Every mating pair is checked against the makers’ documents, never “same as” another board.
4. Heat
About 3.5 W from the RK3576J goes through the heat block into the aluminium L-spreader and on to the steel pole bracket and the 114 mm steel pole (5 K/W est.), so the chip sits near 78 °C with the head at 60 °C inside on a sunny summer afternoon (est.), under its 85 °C rating: to prove on rev A with a logger in a head in the sun. The camera and radar chips are 146 mm or more from the processor.
5. Power budget (est.)
| State | Draw |
|---|---|
| Day: two cameras at 10 fps, radar, models, LTE-M | 6.0 W |
| With the cell charging | about 7 W, 35 % of the 20 W supply |
| Night, quiet street: cameras at 5 fps, radar | 4.5 W |
| Power cut (the crossing is dark): RK3576J asleep, wakes every 60 s to log and send the fault over LTE-M | 0.4 W, about 26 h on the cell |
6. Factory test (every board, every time)
Spring-pin fixture on TP1 and the strips’ pads: 5 V in, the eFuse trip at 3.5 A, every rail, boot from the card, a frame of a test chart from each camera, a corner reflector seen by the radar, all 16 call LEDs, the buzzer, the motion chip, the tamper switch with a magnet, the security chip’s key, the LTE-M and BLE links; on the power board, the supply under load, a test current through each feed sensor read back by the ADC, each controller contact closing into a test detector input, the charger’s temperature cut-off with the thermistor warmed. Each board gets its serial number in the ID chip.
7. Who makes what
One maker makes the rigid-flex piece and the power board, assembles them (turnkey) and makes lead L1 to length. We supply the microSD cards with our software and the lenses focused at 15 m (est.). The quote pack is /build/roadone-quote.
8. Cost per signal head, electronics (est.)
| Item | Cost |
|---|---|
| V2 core (RK3576J, 4 GB LPDDR4X, 32 GB eMMC, power, AP6275S) | $48 |
| Two IMX415 camera chips, holders and lenses | $28 |
| IWRL6432AOP radar chip | $12 |
| BG95-M3 LTE-M, eSIM and antenna | $18 |
| Three feed sensors and the ADC | $9 |
| Three photo-MOS contacts and terminal | $6 |
| 16 call LEDs, two drivers, buzzer | $4 |
| IRM-20-5, terminals, fuse, cell, charger | $20 |
| Security, ID, motion, socket, Hall switch, passives | $8 |
| Boards (8-layer rigid-flex with a 580 mm back strip, three tabs, a 2-layer power board), 1,000 heads | $34 |
| Lead L1 | $2 |
| Assembly and test | $14 |
| microSD card with our software | $4 |
| Total | about $207 per signal head (est.) |
The bench head’s bought boards cost about $330 at qty 1 (Pi 5, two cameras, radar module, clamps, ADC and IMU boards, relays, LED sticks, Walter, supply, backup and small boards), so our boards are about $120 cheaper per head at 1,000 (est.).
9. Timeline
| Step | When |
|---|---|
| Shape and placement (this page) | done, 4 Nov 2026 |
| Rev T CAD: the boards in the signal-head CAD, every part checked in 3D; the approach, crossing and radar windows and the tone holes already moved | next |
| Schematic, footprints, routing | Dec 2026 – Jan 2027 |
| Rev A boards made and tested | Mar 2027 (est.) |
10. Still to check
- The rev T CAD changes still to draw: the L-spreader and its bolts to the pole bracket, the tab brackets, the door magnet boss, the printed light guides and the 120 V shield.
- The head’s inside temperature in full summer sun, logged on rev A; if the chip runs past 75 °C, a larger spreader on the back wall.
- The highway authority’s cabinet wiring rules for the unswitched feed and the detector pairs in the signal cable.
- LTE-M with the steel pole right behind the back wall.
- The F1 and F3 camera-lane impedance over 274 and 131 mm with the flex maker.
Sources
- Rockchip RK3576 brief: https://www.rock-chips.com/a/en/products/RK35_Series/2024/0524/1977.html
- Sony IMX415 (8.46 MP, 4-lane MIPI): https://www.sony-semicon.com/en/products/is/security/security.html
- TI IWRL6432AOP: https://www.ti.com/product/IWRL6432AOP
- TI ADS131M04: https://www.ti.com/product/ADS131M04
- Talema AC10 current transformers: https://www.talema.com/current-transformers
- Panasonic AQY212EH photo-MOS: https://industry.panasonic.com/global/en/products/control/relay/photomos
- Quectel BG95-M3: https://www.quectel.com/product/lpwa-bg95-m3/
- AMPAK AP6275S: https://www.ampak.com.tw/
- Mean Well IRM-20: https://www.meanwell.com/Upload/PDF/IRM-20/IRM-20-SPEC.PDF
- ST LSM6DSOX: https://www.st.com/en/mems-and-sensors/lsm6dsox.html
- Microchip ATECC608B: https://www.microchip.com/en-us/product/atecc608b
- TI DRV5032: https://www.ti.com/product/DRV5032
- Samsung INR18650-35E: https://www.samsungsdi.com/
- NEMA TS 2 traffic controller assemblies: https://www.nema.org/standards/view/traffic-controller-assemblies-with-ntcip-requirements
- The signal head: products/roadone/cad/roadone-cad.mjs (rev A, windows rev T); the boards: products/roadone/hardware/pcb/roadone-board.mjs
Design review (4 Nov 2026)
Every board is checked by the same rules (products/_shared/board-rules.mjs), one for each lesson any of our boards has taught us. RoadOne’s boards were made with every rule from the start: 16 pass, 5 fixed, 12 to prove, 0 fail. The full review, with every number and its source, is on the board page. It shows:
- Camera pixels: a car 60 m up the approach fills about 65 px against a 30 px need; a person reaching the far kerb (8.7 m) about 112 px against 20; both 8 MP chips at 10 fps use 23 % of their links and 166 Mpx/s of the image processor’s 480.
- Every crossing call in view: the first car waiting, the queue 20 m back, a vehicle 60 m out, a cyclist in the kerb lane and the opposing lane; a car over the stop line, people in both lanes and at the far kerb, a near miss and a car stopped on the studs; people waiting at and back from the kerb, stepping on and still in the near lane, from where each lens or chip really sits in its wall.
- The approach camera looks out of the door corner (fixed): from the floor the 60 m count line lies 88° off the window (lesson: window). The crossing window and the radar slot were also sized for our chips (fixed). Drawn in the CAD the same day.
- The controller’s own lamp drive is untouched (fixed): an unswitched supply on a spare conductor, and feed sensors the wires pass through unbroken, so a dead red module is still seen by the controller.
- The latched microSD (J1) is fitted, and our software starts from it; updates run only in the quiet hours, and the controller keeps its own timings throughout.
- A thermistor on the backup cell holds charging outside 0 to 45 °C, and conformal coating against rain and condensation is asked for in the quote.
- Fast lines on a solid ground plane (to prove, lesson: planes, from the CricketOne test-board layout of 4 Nov 2026): RK3576J memory; 2 camera MIPI links (100 Ω pairs); USB (90 Ω); antenna feed (50 Ω, keep-out on every layer); card lines (length-matched, no vias under the socket). Ground on the layer next to the parts (inner layer 1, supply on inner layer 2; the whole bottom of a 2-layer section), one via beside each ground and supply pad and none in pads, no copper or vias in the antenna keep-out on any layer or under the card socket, the impedance lines routed first with a test coupon. The quote asks for it; the routed board’s design rule check proves it.
- To prove on rev A: the head’s temperature in summer sun (78 °C est. at the chip), the AI time, the power-cut run on the cell, LTE-M near the steel pole, the authority’s wiring rules for the controller contacts, 120 V creepage, the tab brackets, the flexes, the tamper magnet and the boards in the rev T CAD.
The request for quote is /build/roadone-quote.